Shaownak Shahriar
Robotics & AI Engineer | Computer Vision & Autonomous Systems
Robotics & AI Engineer building intelligent autonomous systems for real-world industrial and societal challenges. My work spans computer vision, autonomous navigation, embedded AI, sensor fusion, and control systems, from Bangladesh's first autonomous quad-plane VTOL UAV to autonomous underwater vehicles, Mars rovers, rescue robots, and enterprise-scale vision systems. I build complete autonomous platforms, from perception and decision-making to navigation, control, and deployment.
Technical Skills
Robotics & Autonomy
Control, Kinematics & Sensor Fusion
Computer Vision & AI
Edge AI & Deployment
Sensors & Hardware
Communication & Protocols
Languages & Tools
Professional Experience
- Developed an enterprise-scale vision-based workforce intelligence system for Banglalink, processing 10 concurrent IP camera streams in real time.
- Implemented face detection, recognition, and liveness detection for automated attendance, behaviour detection, and unknown-person security alerts.
- Designing scalable AI pipelines and deployment workflows with TensorRT-optimized inference for continuous production operation.
- Engineered and deployed real-time underwater image enhancement pipelines using GAN-based translation to process feeds in low-visibility environments.
- Optimized inference latency by deploying vision models onto NVIDIA Jetson Orin Nano with TensorRT, achieving stable performance for live video streams.
- Integrated Pixhawk, Raspberry Pi, and Jetson-based autonomous control systems with onboard sensors.
- Led the AI & Machine Vision sub-team; the team placed Global 1st Runner-up at RoboSub 2023 and received the Ingenuity Special Award.
- Developed underwater perception pipelines using YOLO, SSD-MobileNet, Mask R-CNN, SAM, and U2-Net with CLAHE enhancement, deployed on Jetson Orin Nano with TensorRT.
- Integrated the Pixhawk vehicle controller and VectorNav INS with the onboard AI computer and designed the onboard communication architecture.
- Collected underwater datasets and ran pool and open-water tests to validate navigation, sensing, and control.
- Led the AI & Autonomous Systems sub-team; the rover placed Global 7th at the International Rover Challenge 2023 and competed at the University Rover Challenge 2023 (Utah, USA).
- Designed real-time state estimation and localization using ROS-based SLAM and sensor fusion (Kalman/Madgwick filters) across LiDAR, GPS, IMU, and RealSense.
- Implemented inverse kinematics for a 6-DOF robotic arm and tuned closed-loop PID control for precise actuator and motor driver stabilization.
- Trained detection models (YOLO, Faster R-CNN, SSD) for terrain perception and autonomous component picking.
Leadership, Teaching & Community Engagement
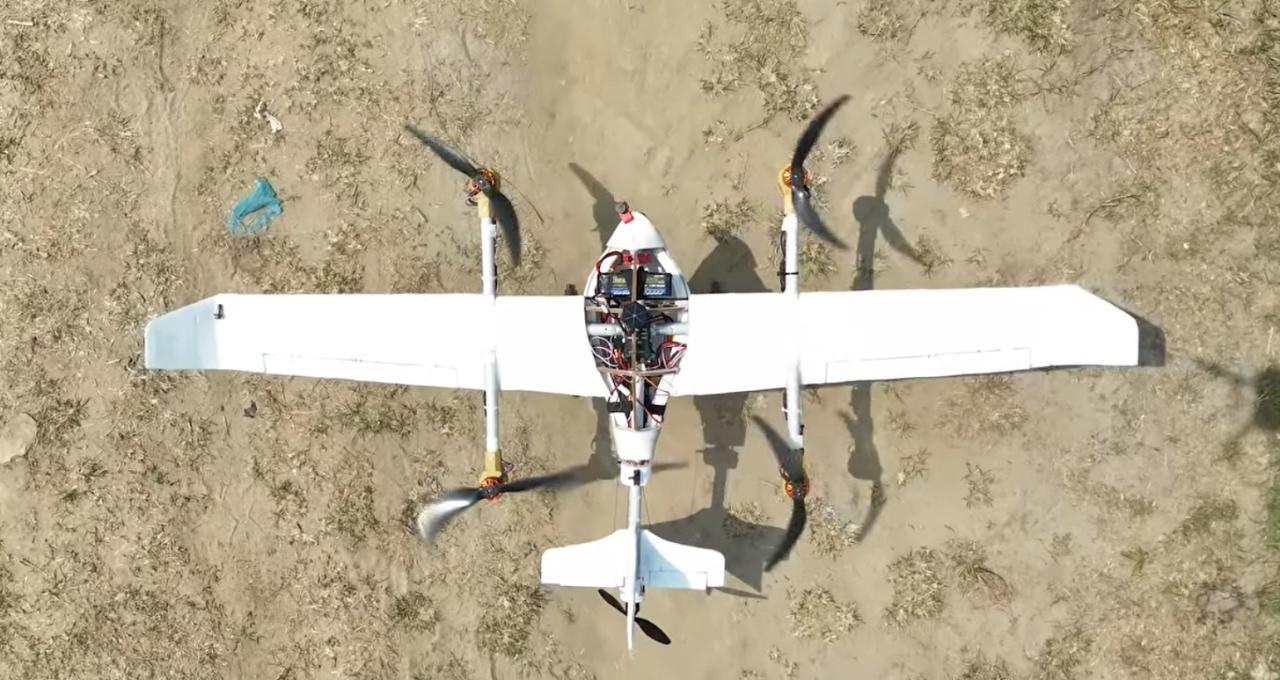
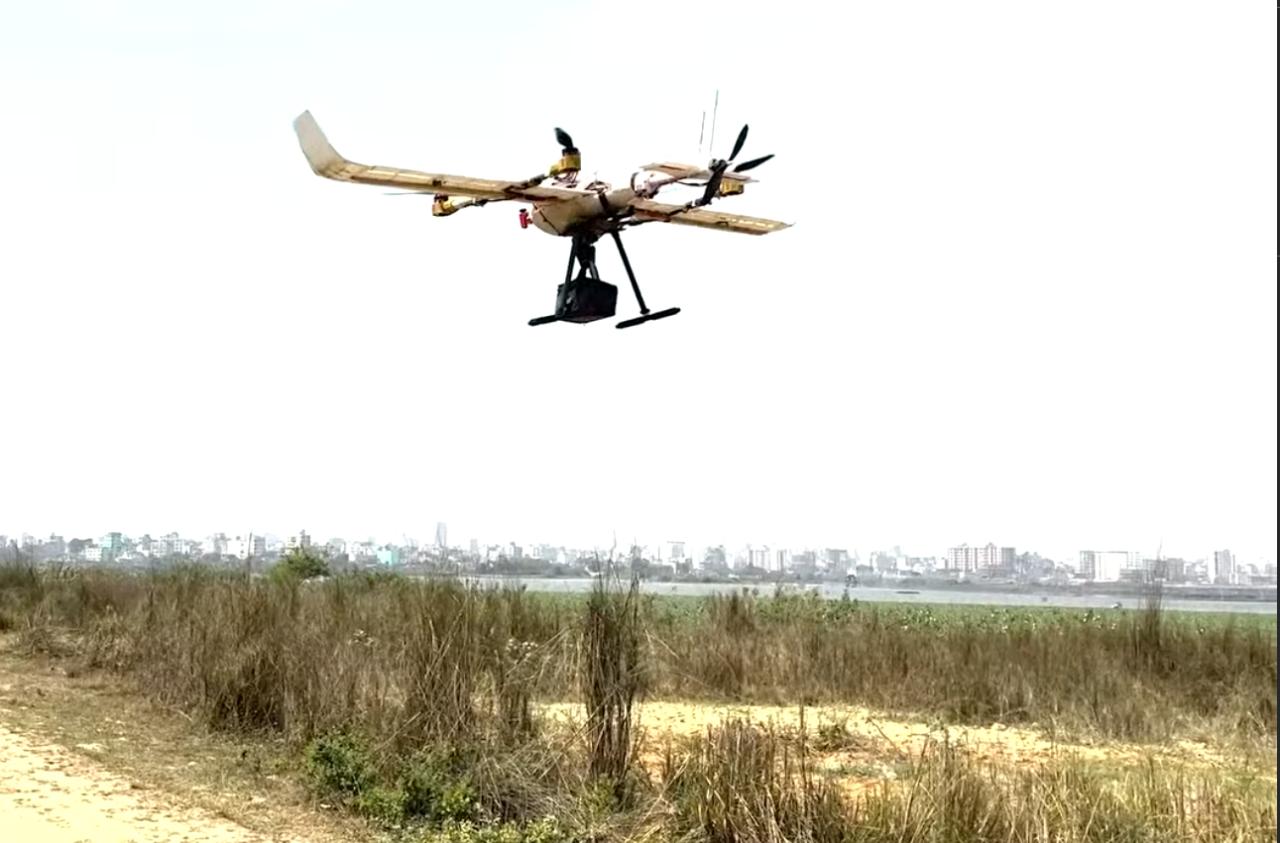
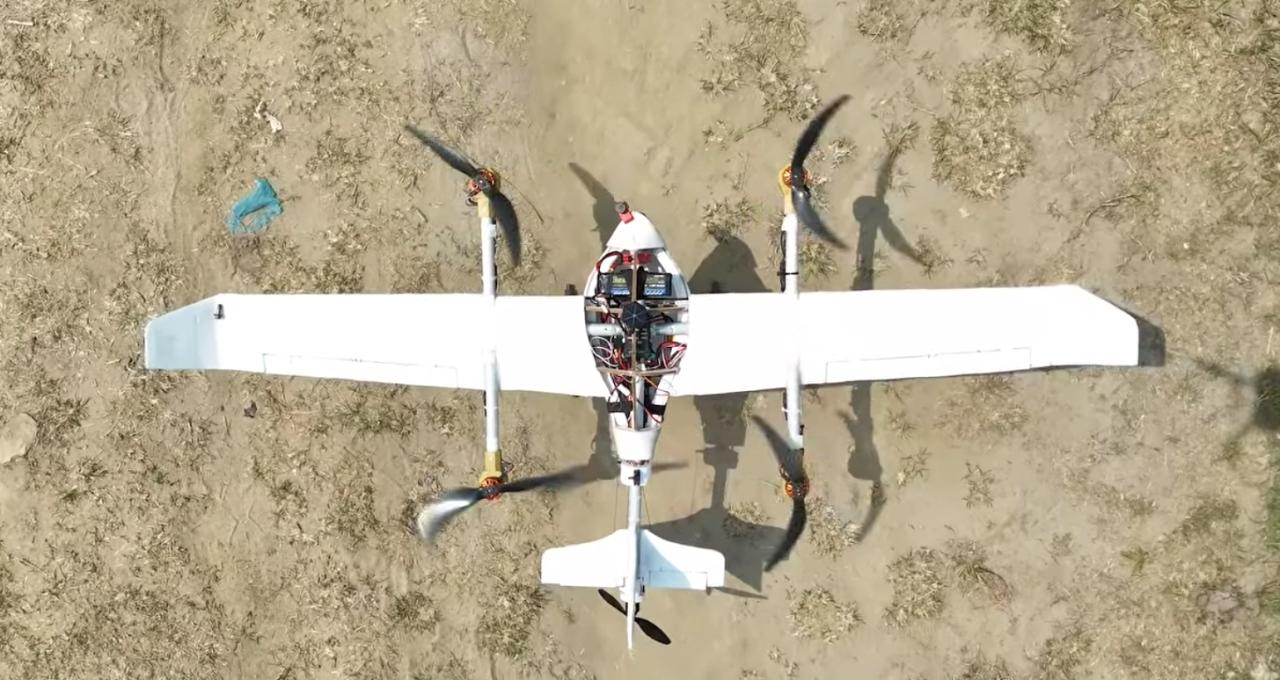
- Co-founded the development of Bangladesh's first autonomous quad-plane VTOL UAV and led the Autonomous & Navigation sub-team.
- Configured and tuned the Pixhawk 6X / ArduPilot flight stack for VTOL and fixed-wing flight, with a Raspberry Pi 4 companion computer, GNSS, and MAVLink telemetry.
- Built autonomous take-off and landing, waypoint navigation, VTOL transition, return-to-launch, and onboard helipad/crowd detection (SSD-MobileNet, TensorFlow Lite).
- Represented the team at the IMechE UAS Challenge 2024 in Leicester, England.
- Successfully deployed the drone in a flood rescue mission in Feni, delivering relief supplies to affected communities.
- Featured in leading media outlets including Prothom Alo, The Daily Star, and Robi Axiata.
- Conducted market research and stakeholder analysis for drone-based delivery and rescue services in Bangladesh.
- Initiated discussions with industry partners to explore collaborative drone surveillance and emergency response solutions.
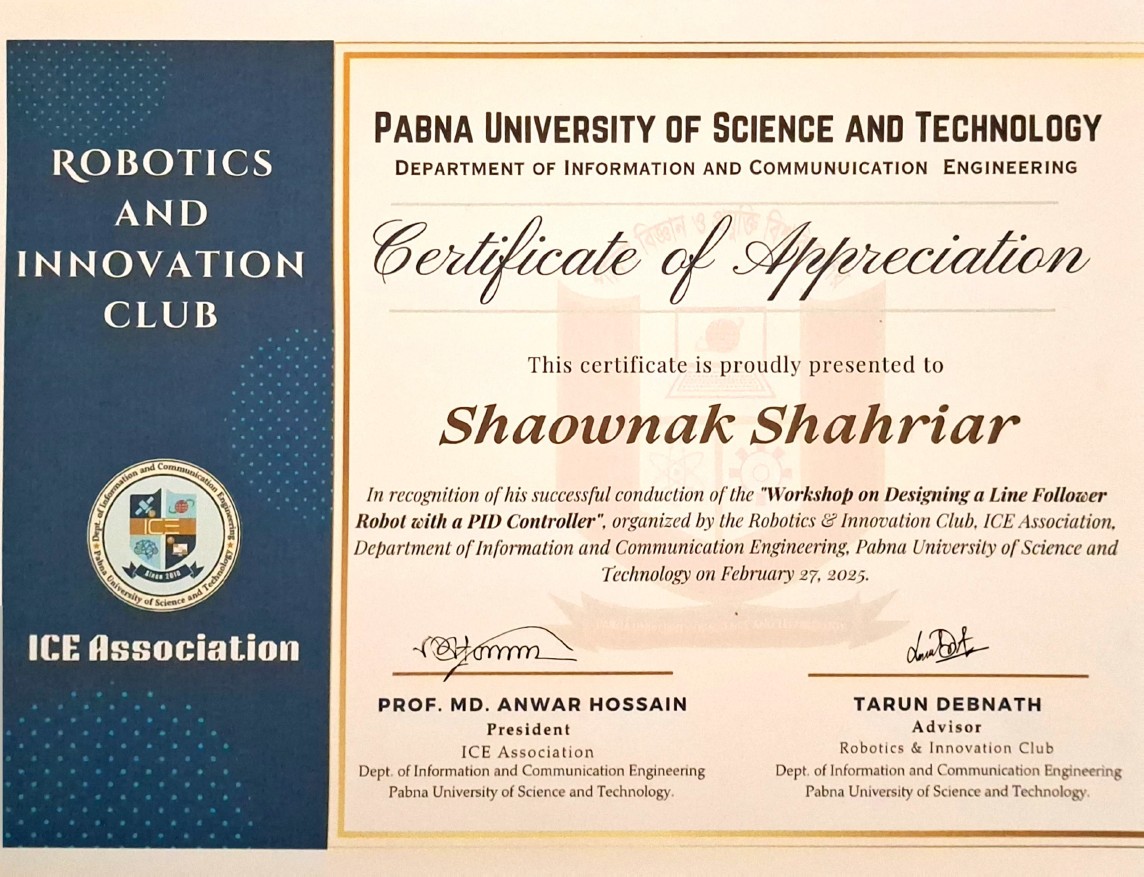
- Invited as a guest instructor to deliver specialized training and guidance on robotics and autonomous systems for university students.
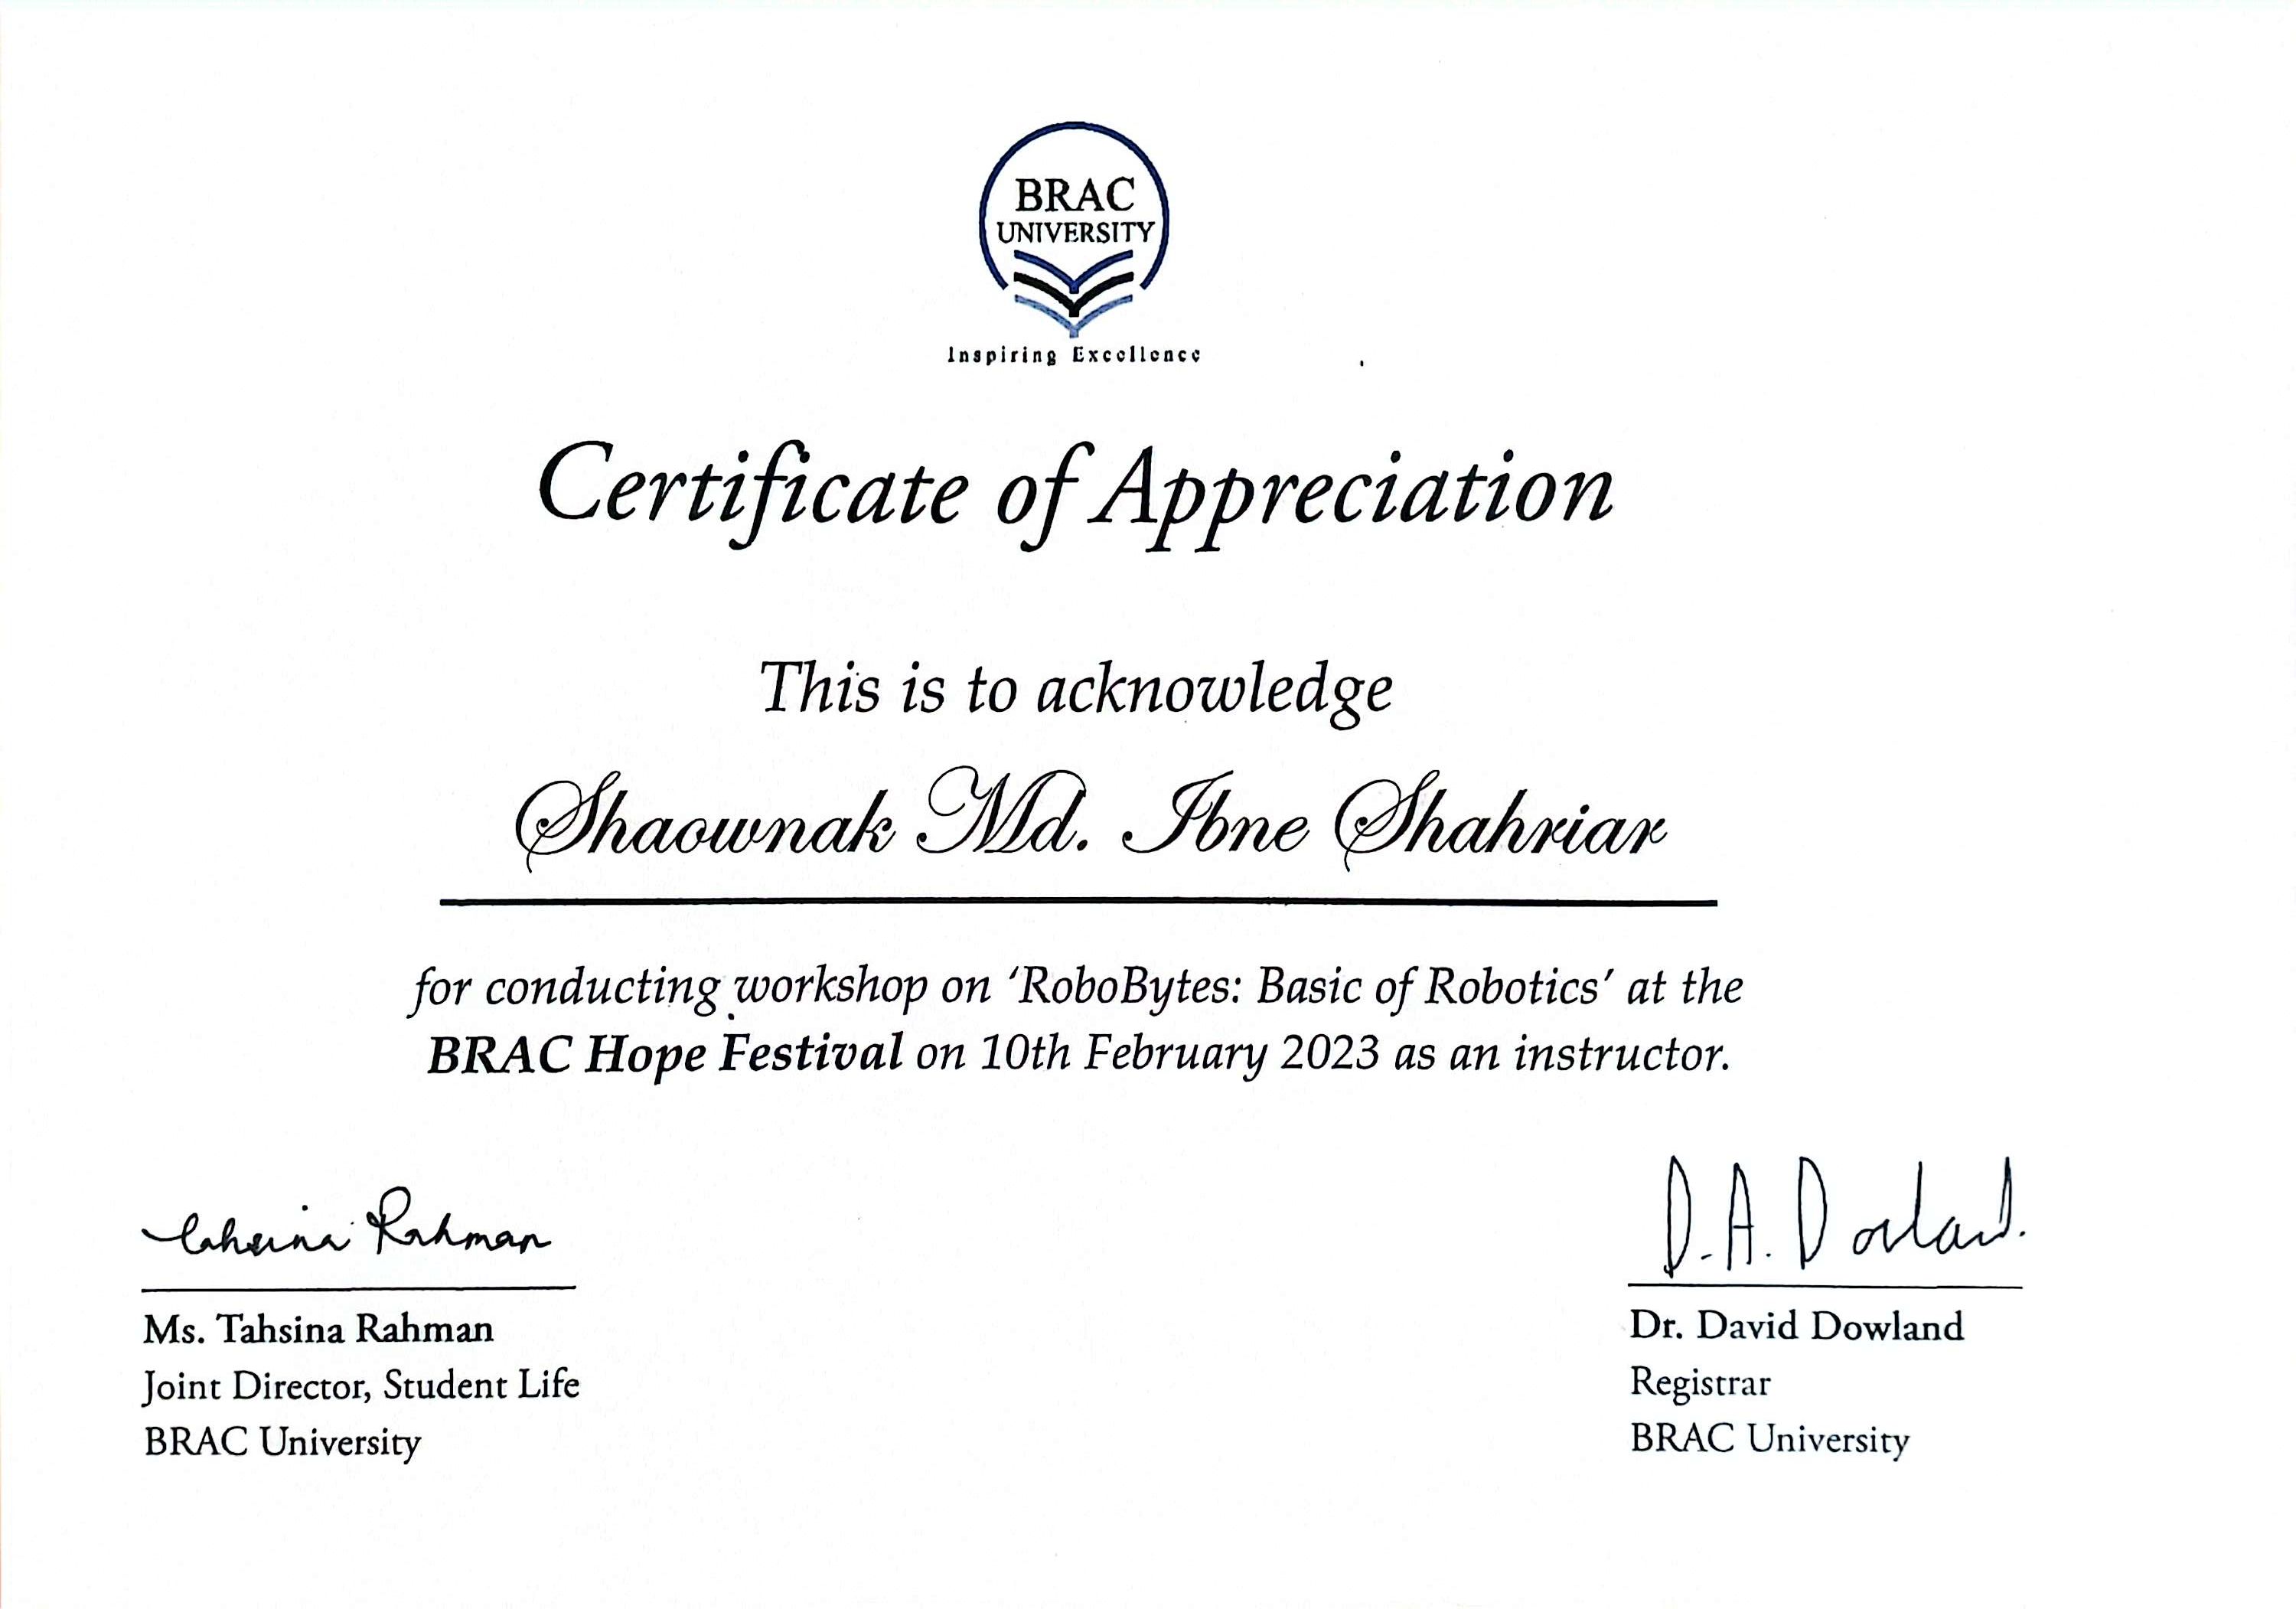
- Taught the "Introduction to Robotics" course at BRAC University Residential Semester for three consecutive semesters.
- Instructed hands-on sessions at the BRAC Hope Fest in June 2023.
- Organized and conducted multiple technical workshops including "Basics of Robotics" and "Introduction to Computer Vision".
- Built and maintained strong community connections within the robotics and academic sectors.
Education
- Currently pursuing advanced coursework focusing on Data Science, machine learning algorithms, and advanced computing infrastructure.
- Thesis: GLE-SSD-VR: Point-Cloud-Based 3D Object Detection for Unmanned Ground Vehicles (Awarded Best Thesis of the Year 2024).
- Research Interests: 3D Object Detection, Underwater Vision Enhancement, UAV Autonomy, Imitation Learning for Robotic Control.
- Notable Courses: Quantum Computing, Artificial Intelligence, Neural Networks, Robotics, Pattern Recognition, Software Engineering, System Design.
- Mentorship: Mentored 4 undergraduate thesis groups on applied Computer Vision research (including Driver Safety, Breast Cancer Detection, and Underwater Waste Detection).
- Competitions: Represented BRAC University in multiple International Robotics Championships (UGV, AUV, UAS), national robotics competitions, and Intra-University Programming Contests (IUPC).
- Key Involvement: Co-Founder & Autonomy Lead of RaptorX, AI & Autonomous Systems Lead at Mongol-Tori, and AI & Machine Vision Team Lead at BRACU Duburi.
Academic Thesis
- Proposed a hybrid GLE-NetVR + SE-SSD voxel-point architecture for real-time LiDAR-based 3D object detection.
- Trained and benchmarked on the KITTI dataset for vehicles, pedestrians, and cyclists, achieving 88% detection accuracy.
- Implemented 3D bounding box regression with spatial attention to enhance accuracy and reduce inference latency.
- Recognized as Best Thesis of the Year 2024 by the Department of Computer Science.
- Submitted to the CVPR 2026
Selected Projects
Robotics & Autonomous Systems
Built an autonomous search-and-rescue robot to assist first responders: AI-based victim detection, autonomous navigation and obstacle avoidance, and delivery of medical supplies in hazardous environments, demonstrated in simulated disaster scenarios.
Developed a mobile robot that detects objects in real time and navigates accordingly, linking a YOLOv3/OpenCV vision pipeline to Arduino-based motion control over serial UART for obstacle-aware autonomous movement.
Implemented a real-time Kalman Filter fusing MPU6050 accelerometer and gyroscope data for stable roll and pitch estimation, reducing sensor noise and drift for UAVs, mobile robots, and autonomous systems.
Built a distributed gas leak detection and automatic shut-off system: ESP32 sensor nodes publish gas readings over MQTT to a Raspberry Pi controller that closes an automated valve when a leak passes a safe threshold.
Computer Vision & Embedded AI
Production-grade AI platform built at Roboway Technologies for Banglalink: processes 10 concurrent IP camera streams for face recognition with liveness detection, automated attendance, behaviour detection (absence, sleep, phone use), unknown-person alerts via Telegram, and a live analytics dashboard.
Built at Dubotech: implemented FUnIE-GAN alongside CLAHE, histogram equalization, and auto color correction to restore color and contrast in low-visibility underwater footage, comparing methods qualitatively and quantitatively for AUV perception and marine inspection.
Developed a real-time driver monitoring and road perception system on Jetson Nano: drowsiness, yawning, distraction, and phone-use detection, plus lane detection and car distance via monocular depth estimation, with visual and audible alerts.
Fine-tuned YOLOv11 with DeepSORT tracking and deployed it on a Raspberry Pi 4B to detect and track UAVs from another UAV in real time, using edge-inference optimizations to maximize frame rate and minimize latency.
Developed a spatial-temporal traffic prediction framework for Dhaka's road network using Graph Neural Networks, LSTMs, and XGBoost ensembles on OSMnx road data, with interactive visualization for route optimization and logistics planning.
Software & Applied ML
Designed scalable asynchronous microservices for automated CV analysis and LLM-based ranking. Built a robust NLP platform using Transformers for intelligent semantic matching, with a backend infrastructure engineered to handle asynchronous tasks and API rate limiting.
Integrated Retrieval-Augmented Generation (RAG) into a full-stack blogging platform to provide AI-driven dynamic content summarization and intelligent semantic search capabilities.
Developed a secure, end-to-end encrypted messaging platform featuring robust user authentication and cryptographic message hashing to prioritize data privacy.
Built comprehensive Enterprise Resource Planning software tailored for e-commerce operations, focusing on scalable database management and robust backend services.
Built a centralized university web application allowing students to easily report and track lost items securely across campus.
Designed and evaluated multiple deep learning architectures including LSTM, BERT, GRU, and Conv1D for advanced natural language processing and robust sentiment classification.
Engineered an accurate real estate valuation tool by fine-tuning XGBoost and custom Neural Networks to predict housing prices based on multifaceted property data.
Featured In & Media Coverage
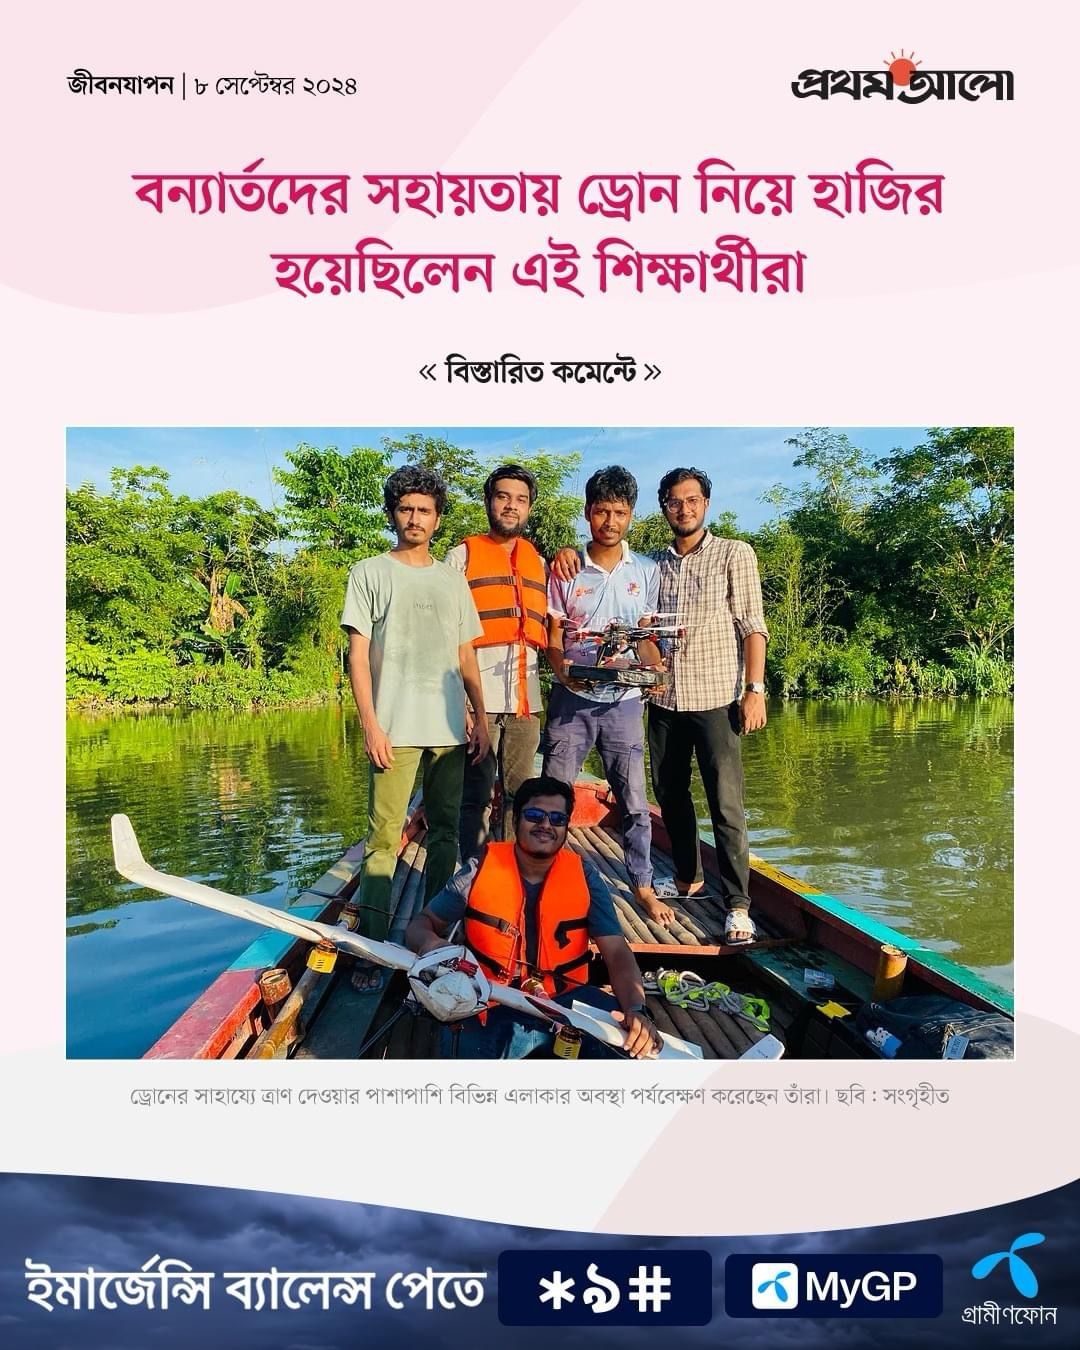
Prothom Alo
Featured for flood rescue operations and autonomous VTOL innovations with RaptorX.
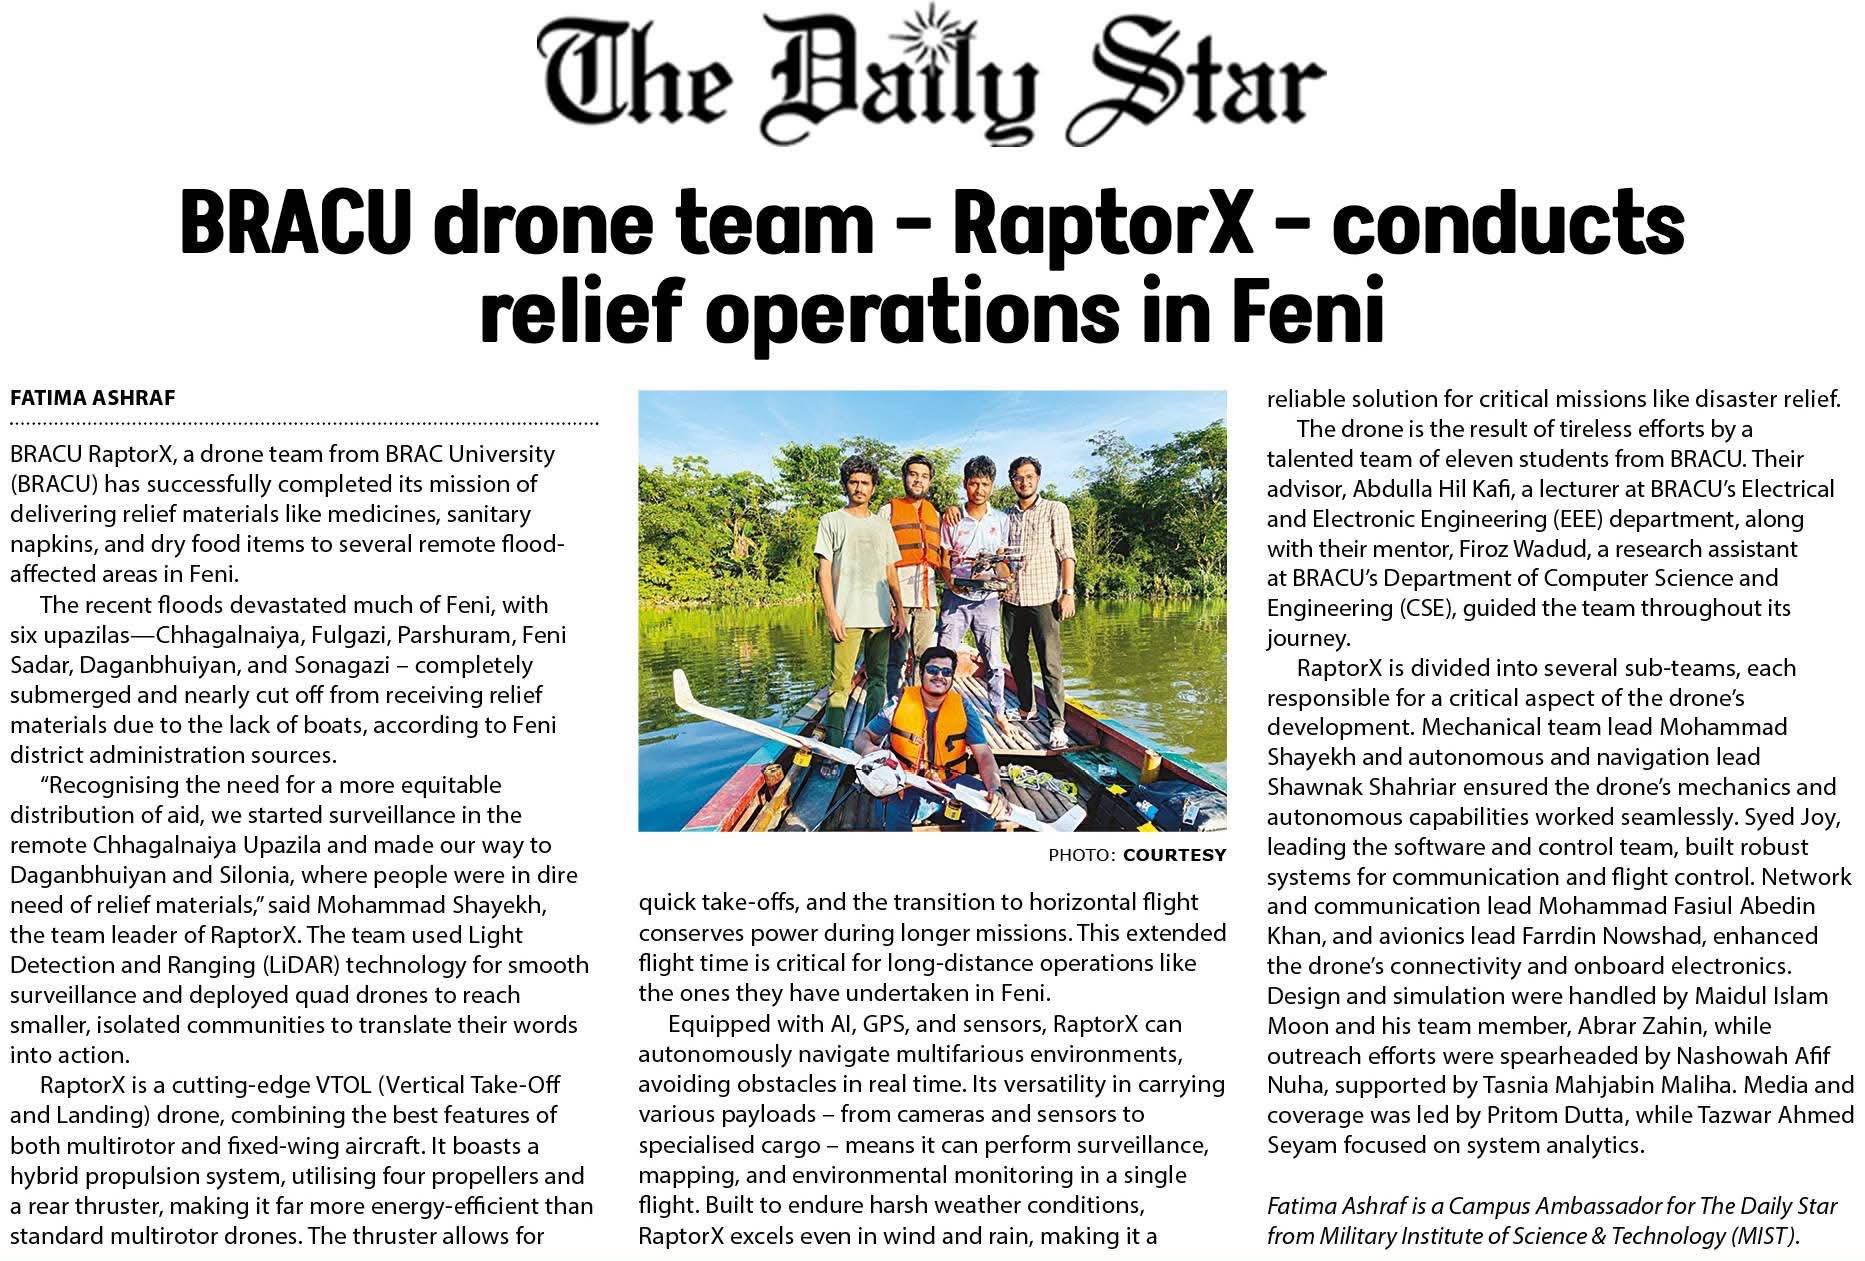
The Daily Star
Highlighting the impact of our drone deployment for delivering relief supplies in Feni.
Robi Axiata
Coverage of innovative robotics and automation projects built during academic research.
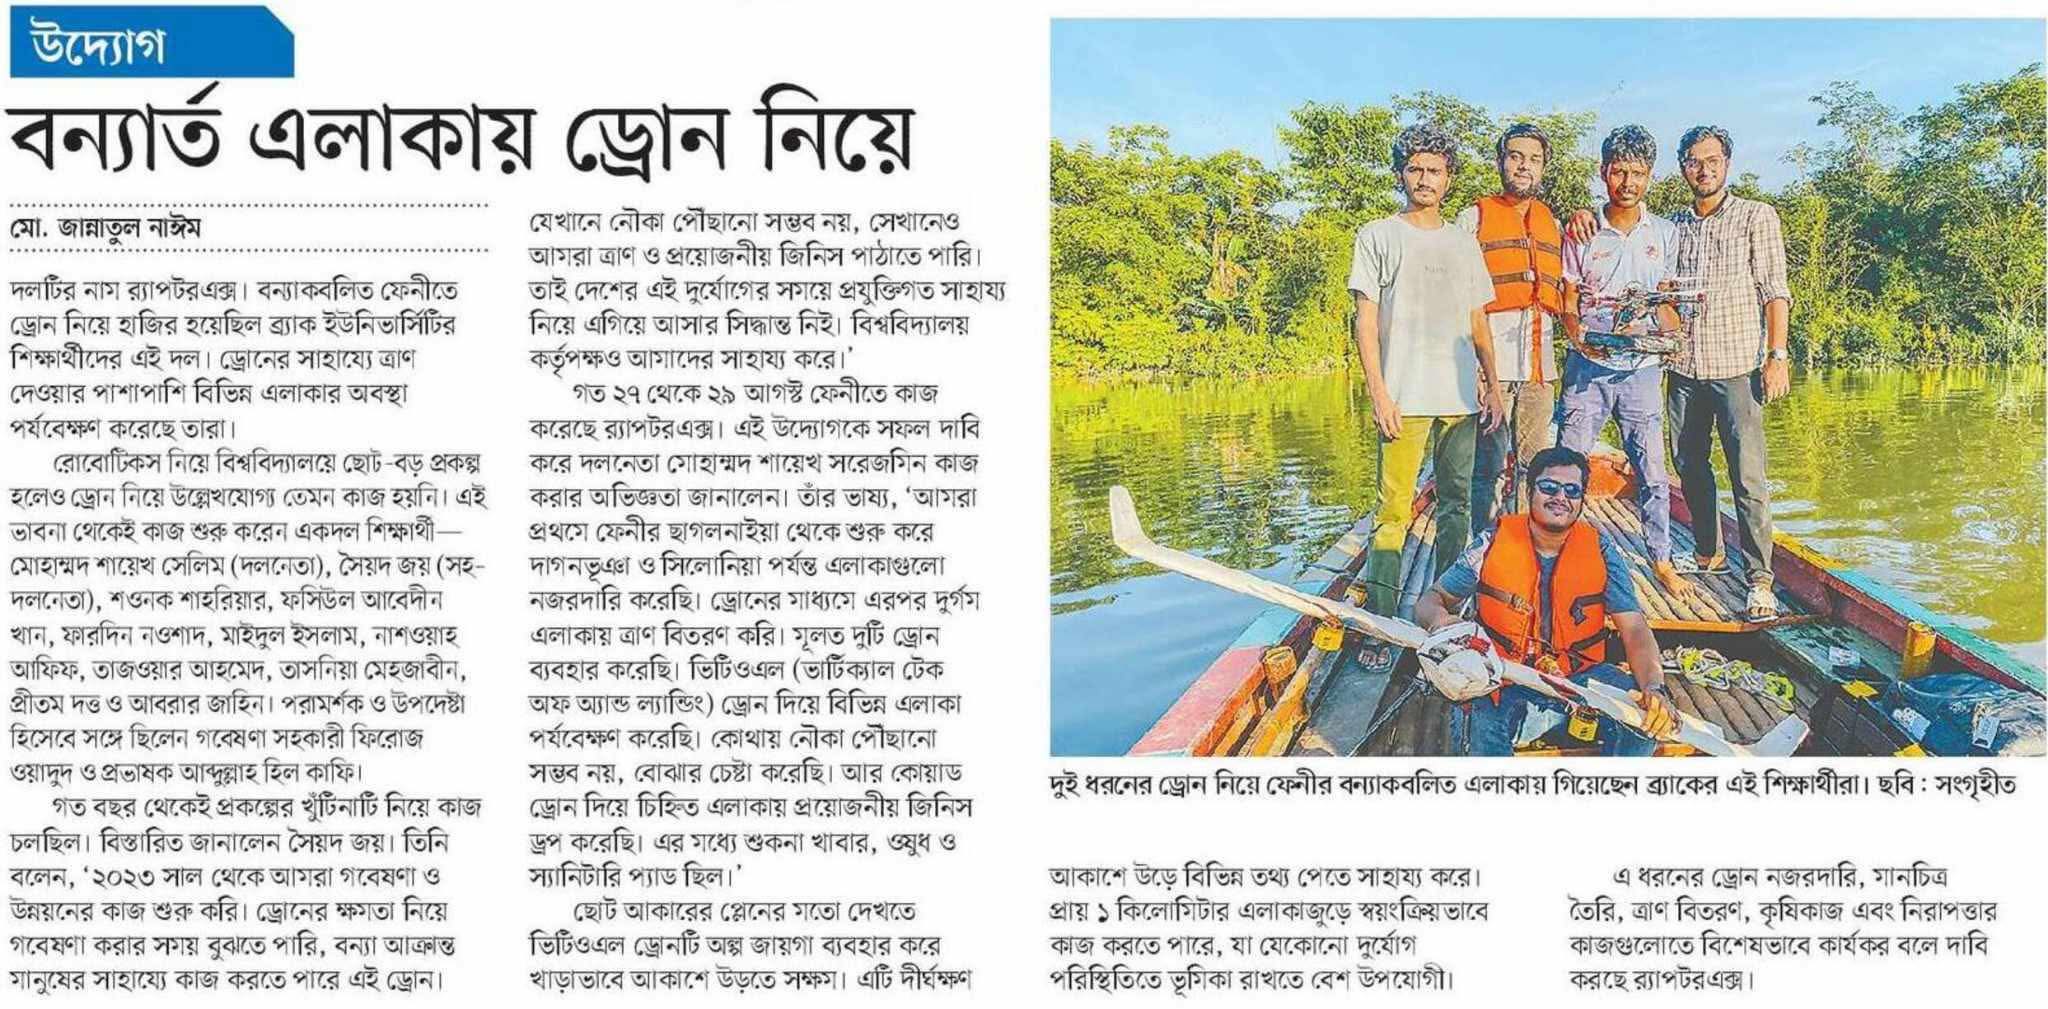
Prothom Alo
Further coverage of RaptorX's development, testing, and representation at the field mission.
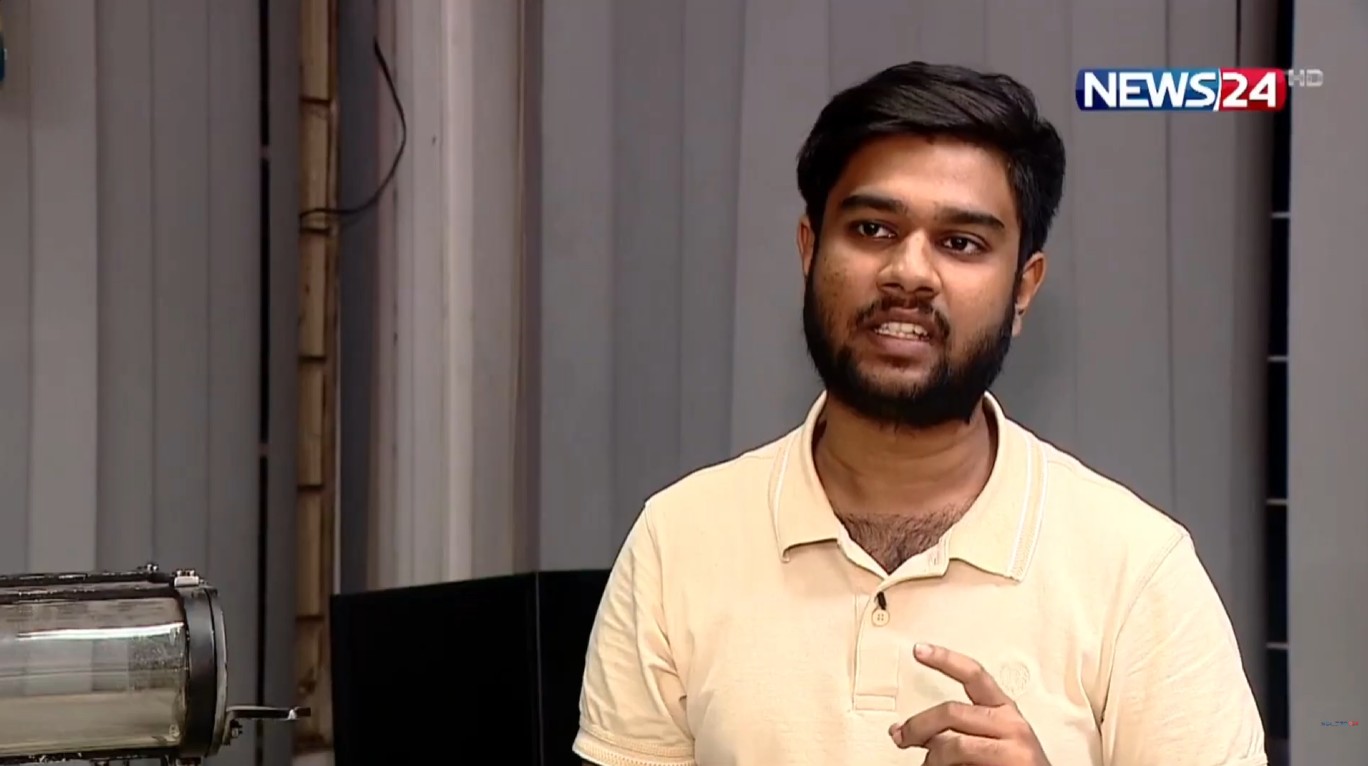
News24
Special feature on BRACU Duburi showcasing pioneering autonomous underwater vehicle (AUV) research.
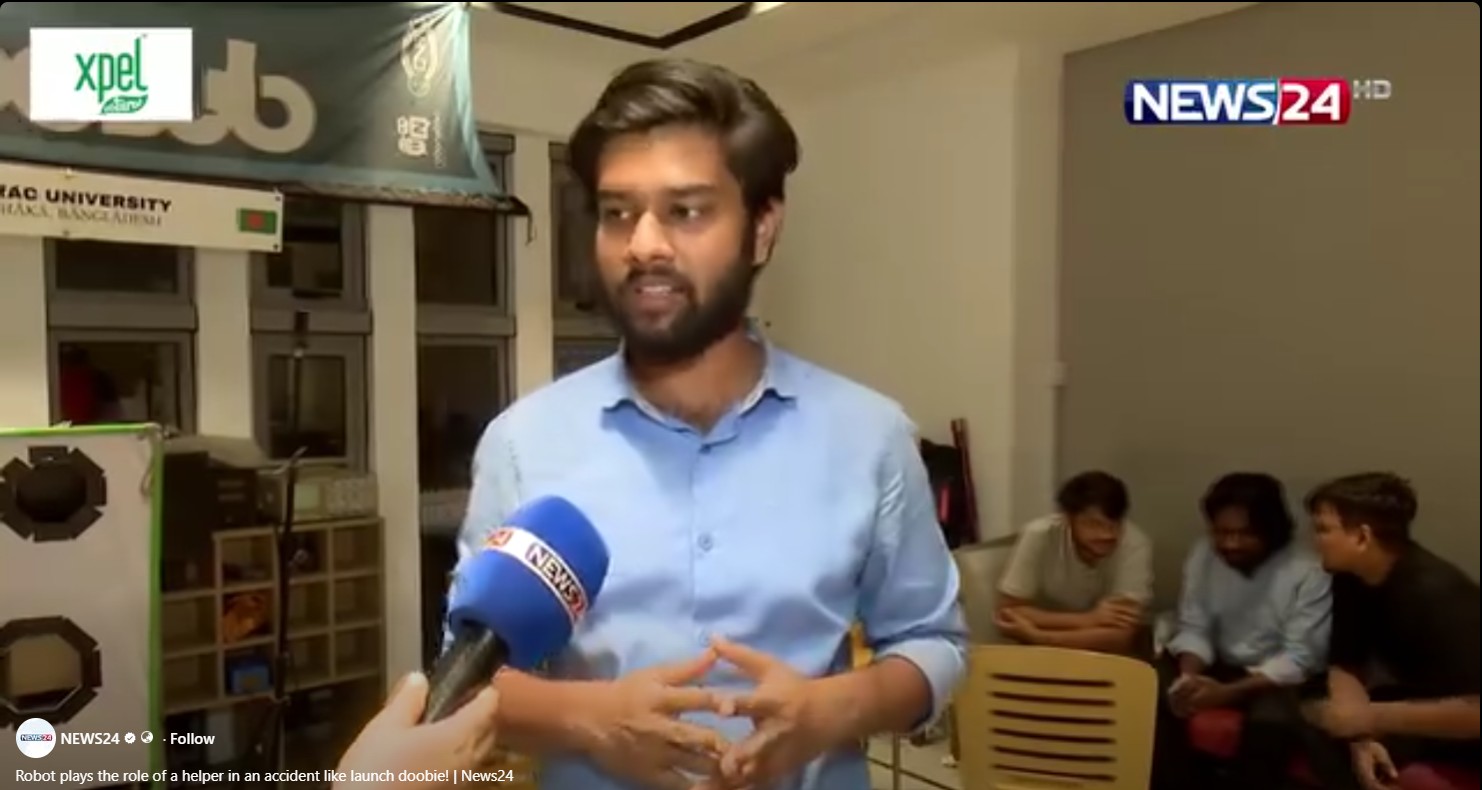
News24
Broadcast coverage highlighting Duburi's real-time underwater AI vision pipelines and robotics innovations.
BRACU Duburi AUV
Field testing with the BRACU Duburi team, pioneering autonomous underwater vehicle (AUV) research and real-time vision pipelines.
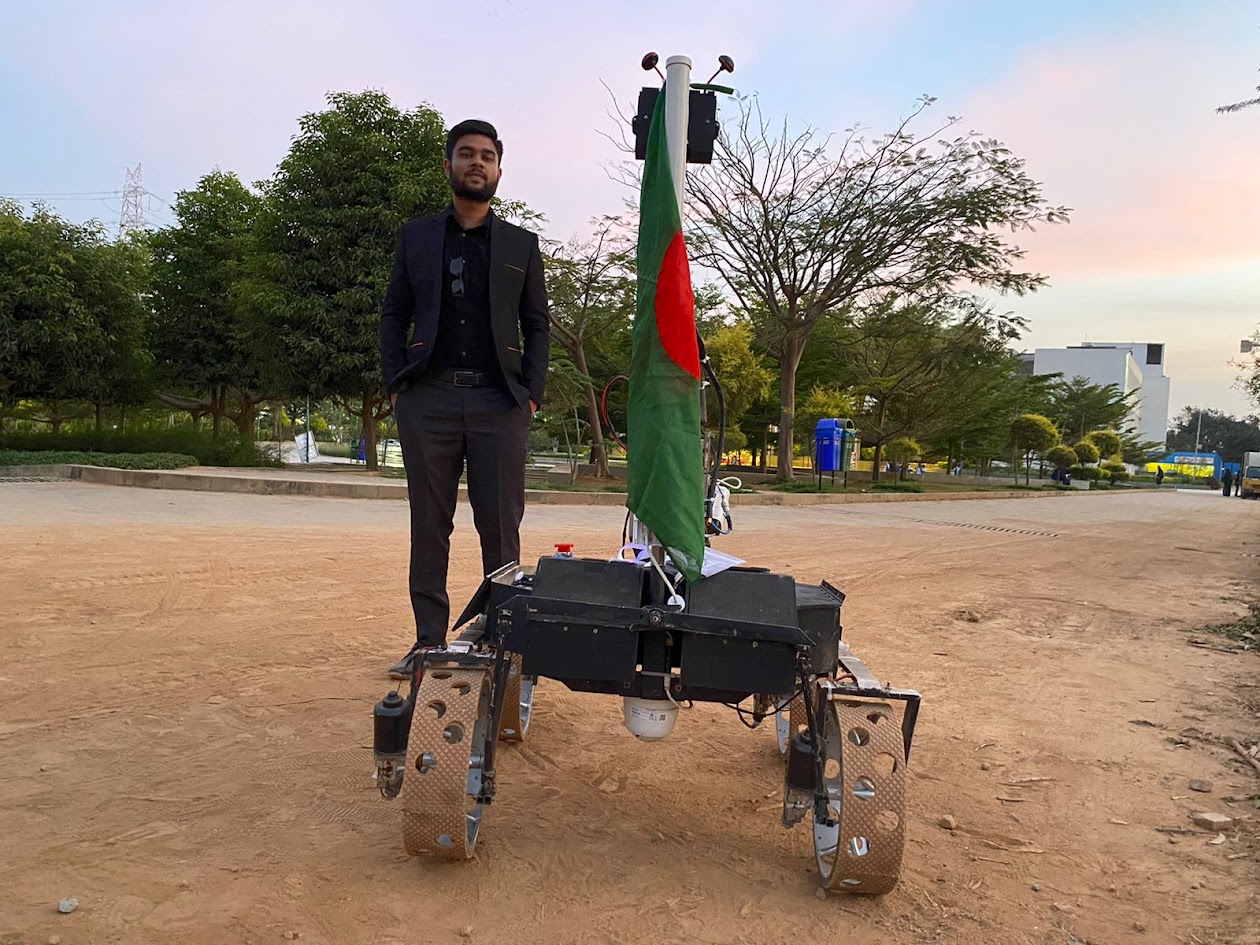
BRACU Mongol-Tori
Showcasing our custom-built Mars rover prototype, featuring terrain-aware SLAM mapping and ROS-based autonomy.
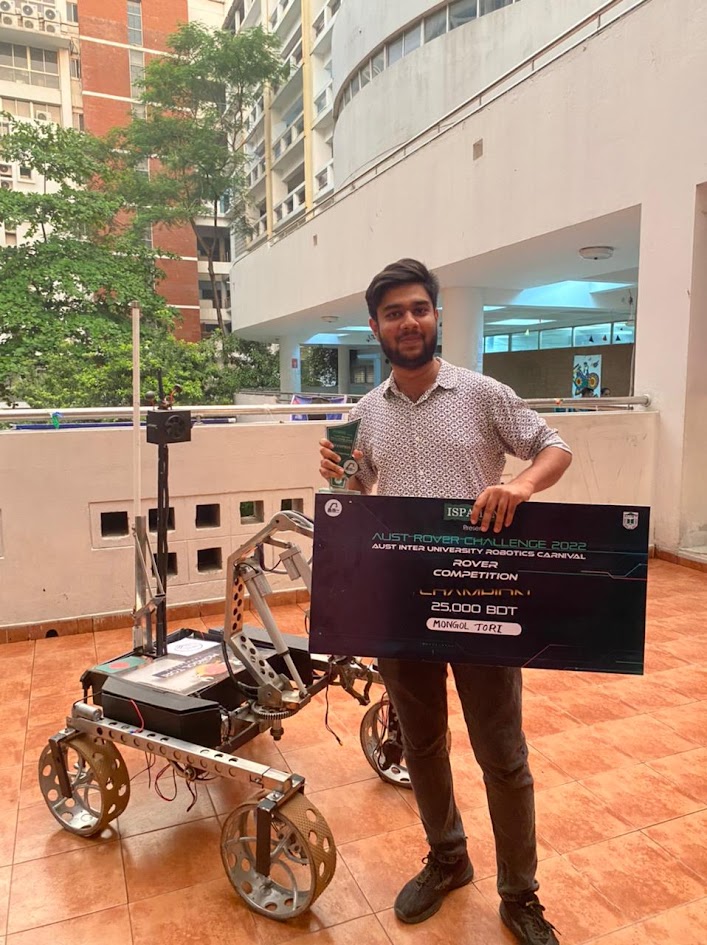
AUST Rover Challenge Champion
Celebrating our championship victory at the AUST Inter-University Robotics Carnival with the Mongol-Tori team.
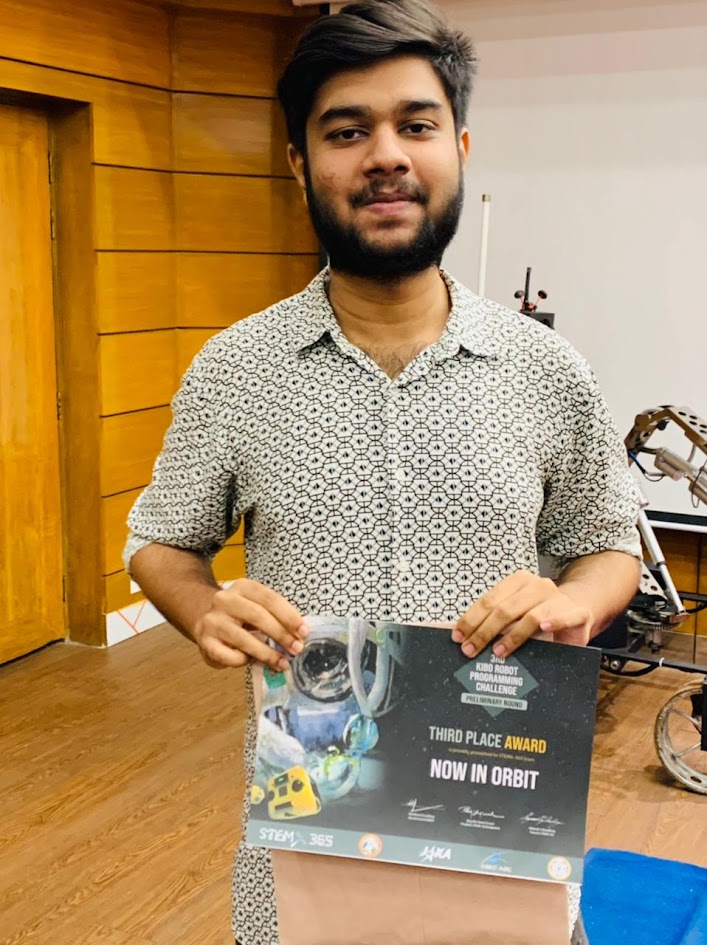
Kibo Robot Programming Challenge
Receiving the 3rd Place Award in the prestigious JAXA Kibo Robot Programming Competition (Bangladesh Round).
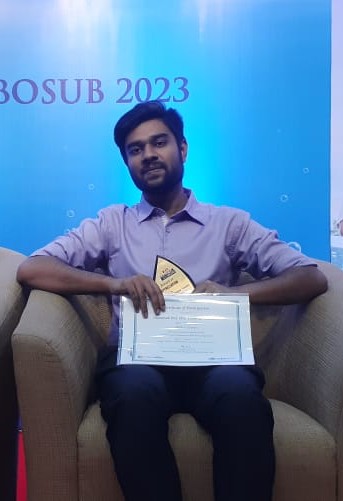
ROBOSUB 2023
Honored as the 1st Runner-up globally at the RoboNation ROBOSUB 2023 competition in San Diego, California.
Global Achievements & Awards
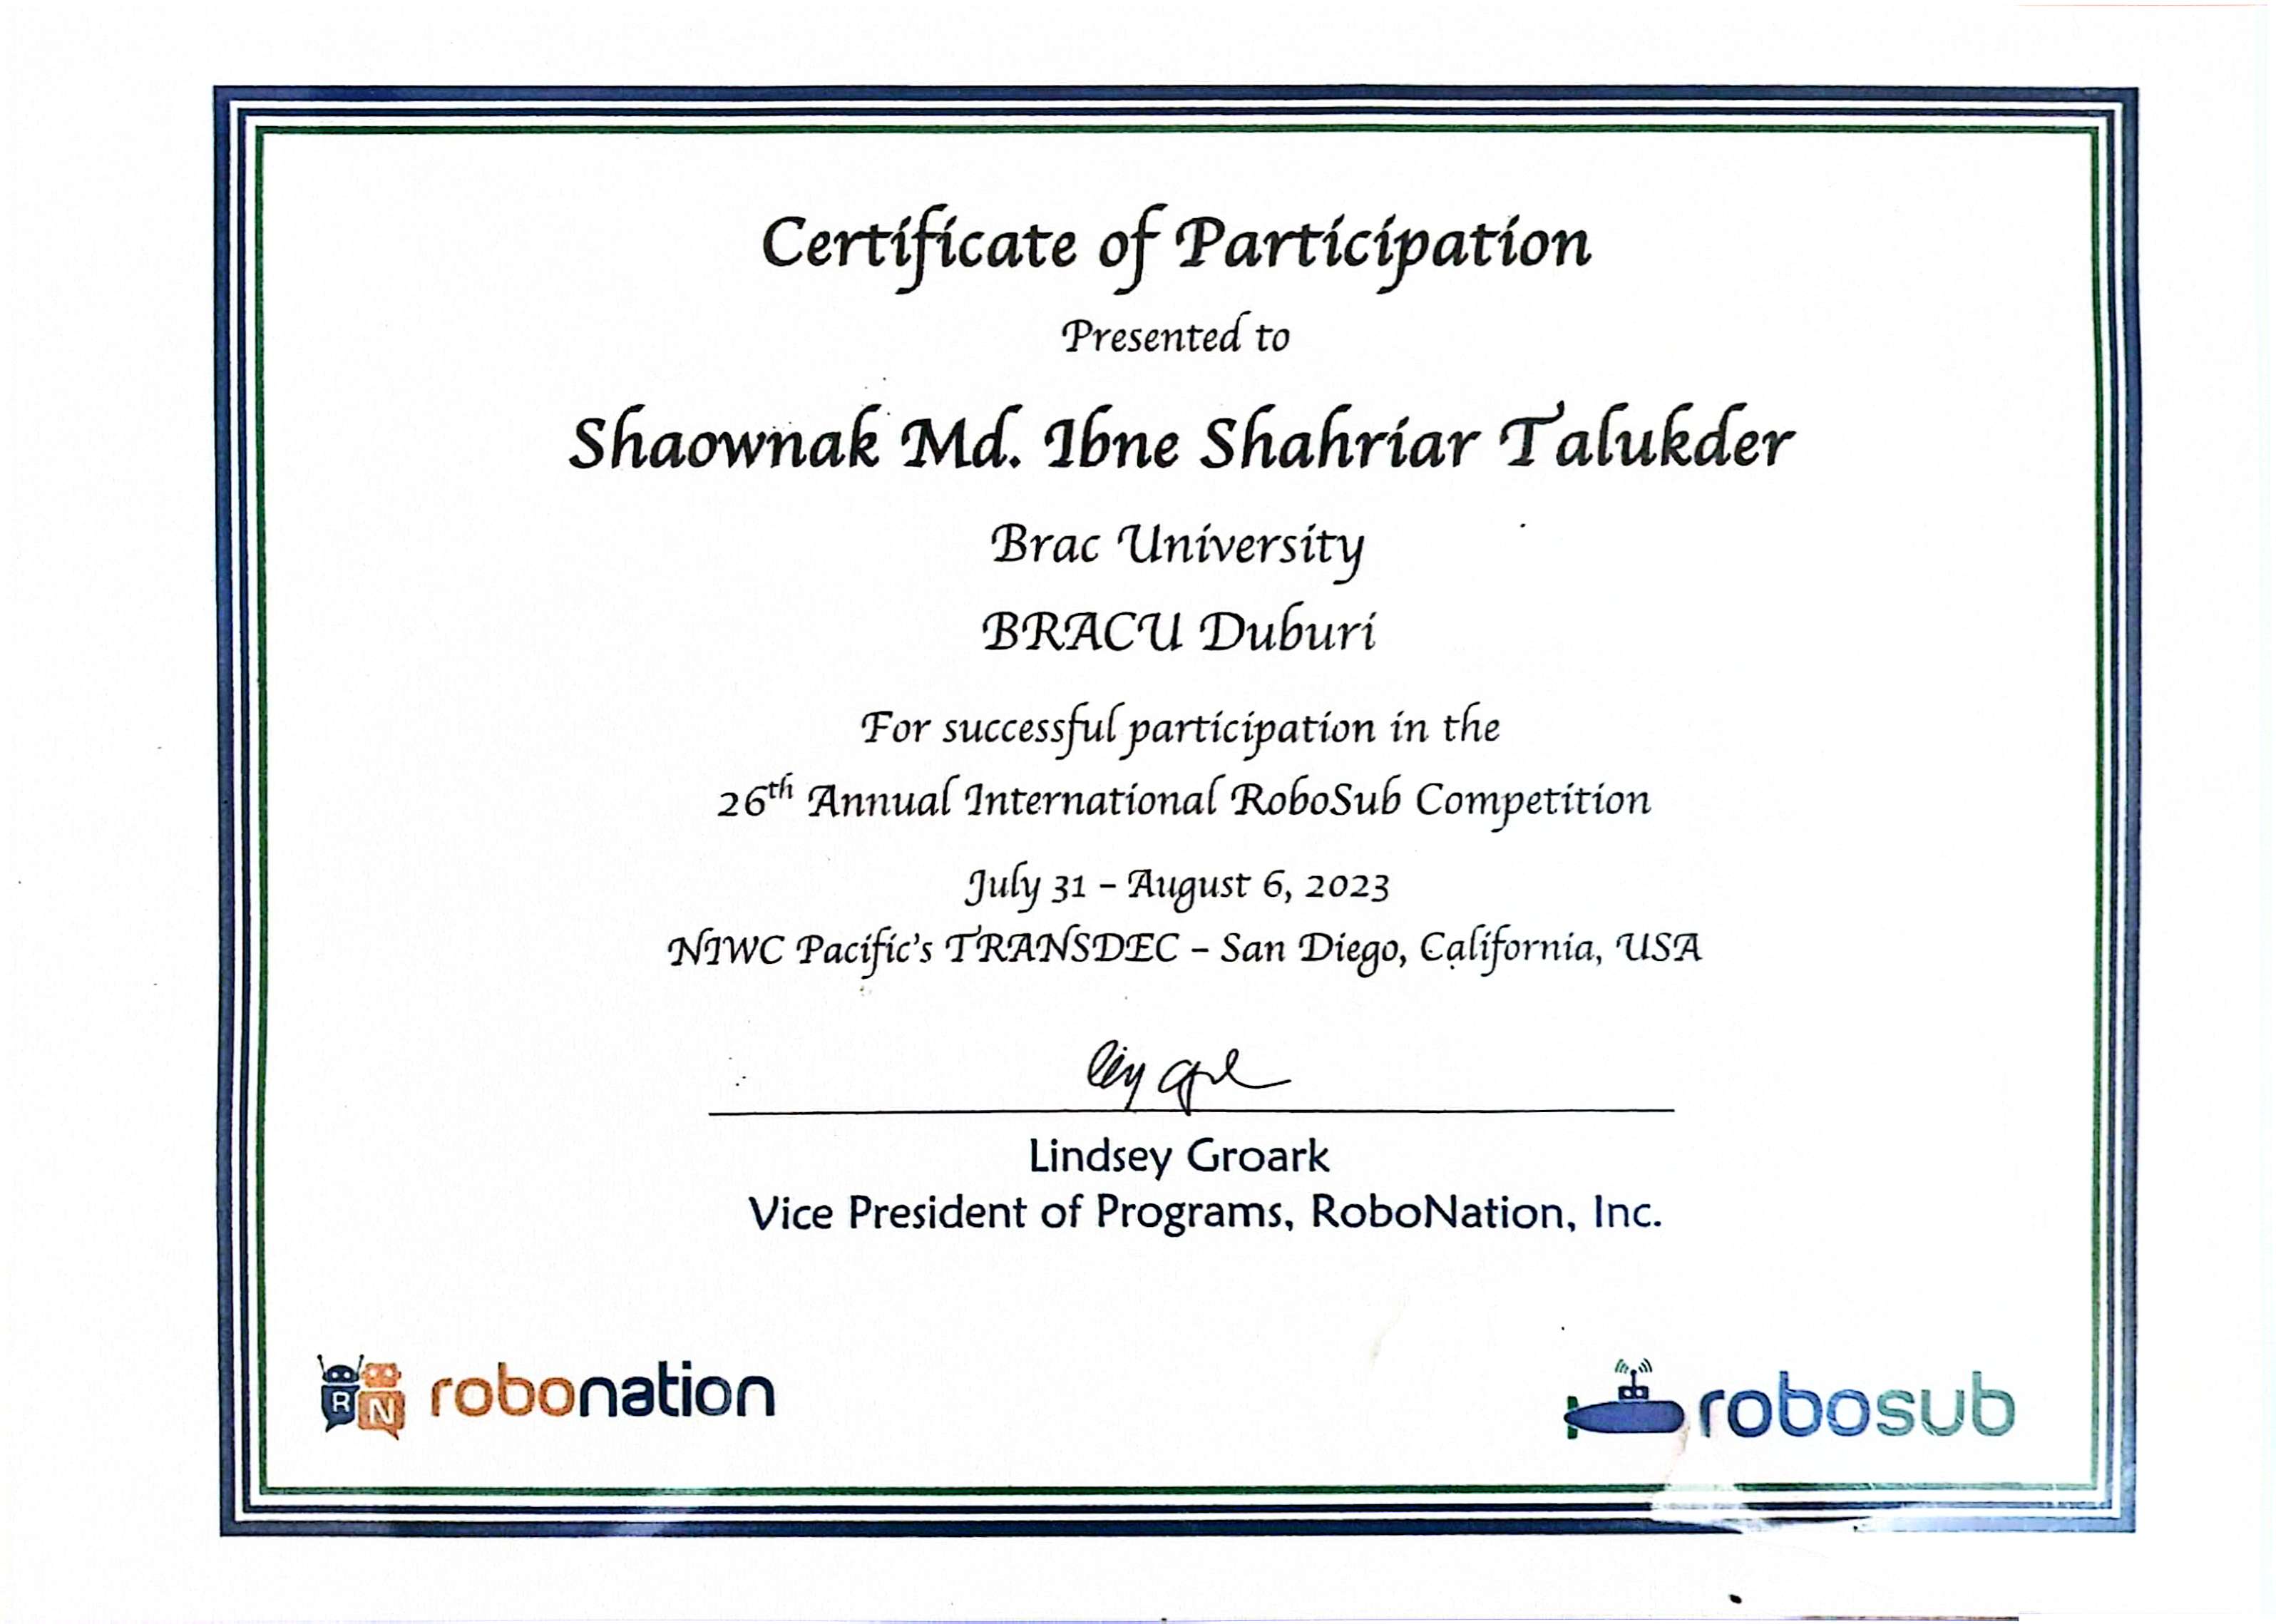
San Diego, California, USA
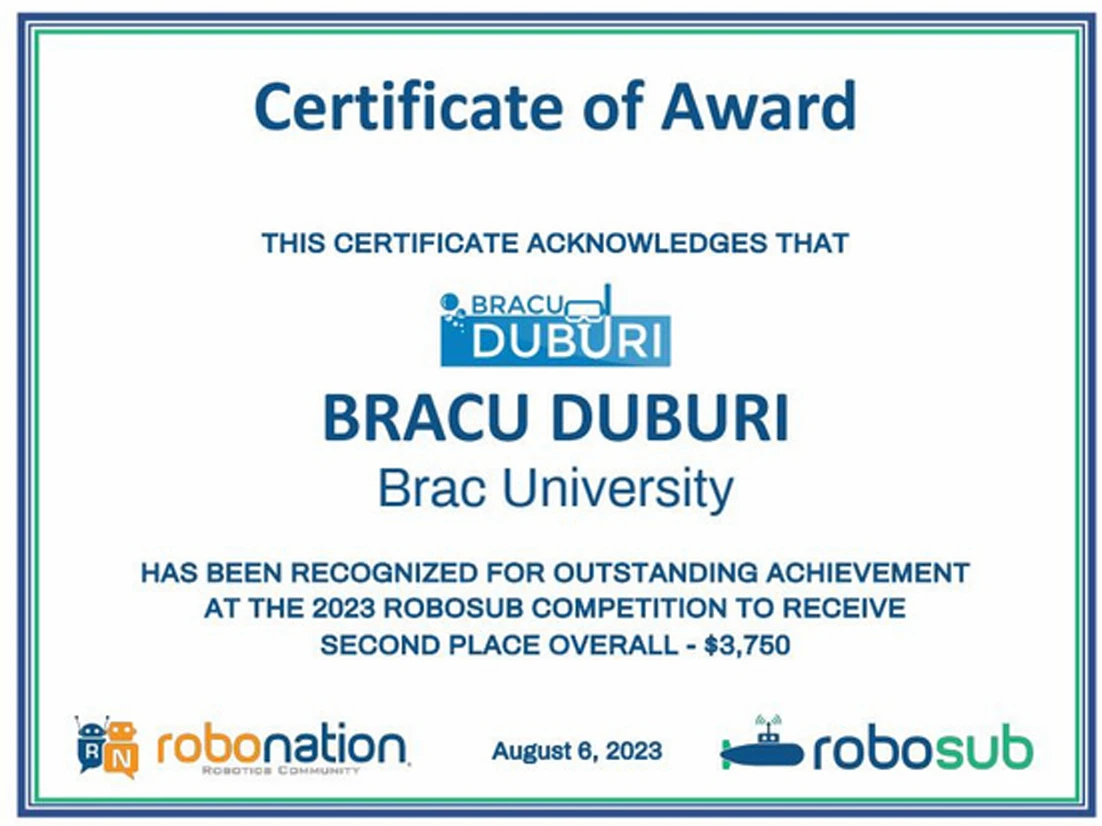
Awarded August 6, 2023
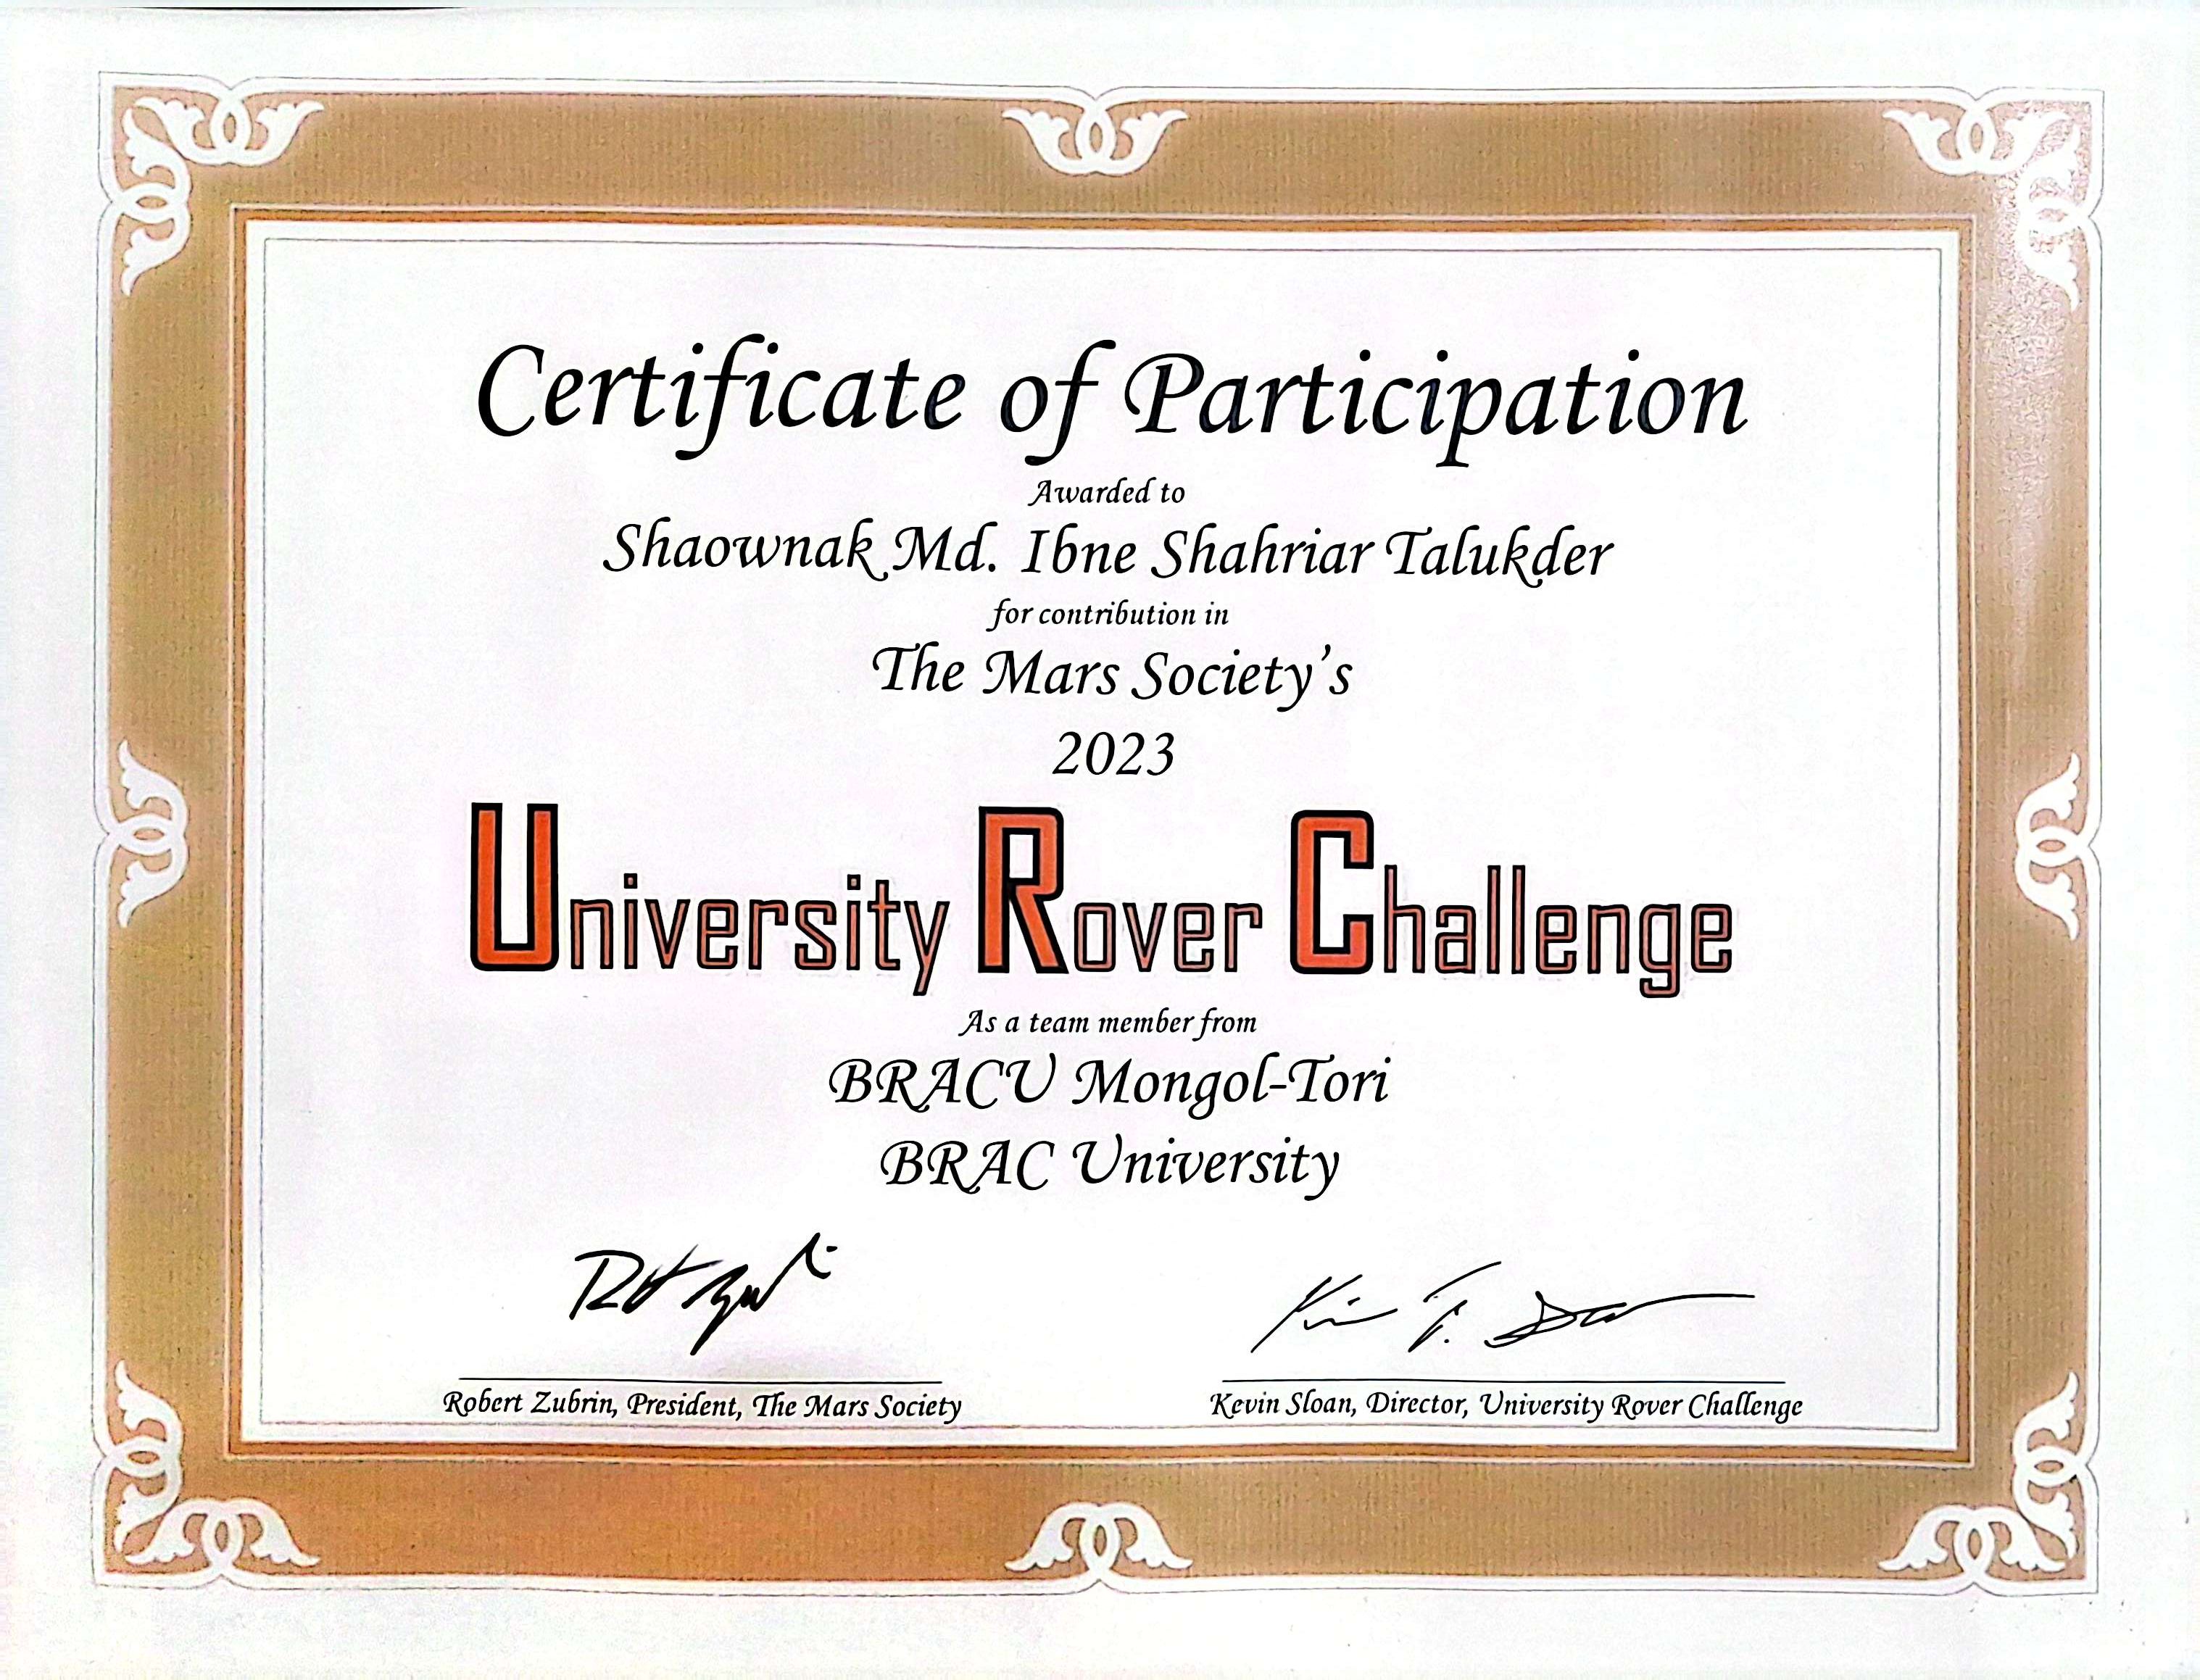
The Mars Society (Utah, USA)
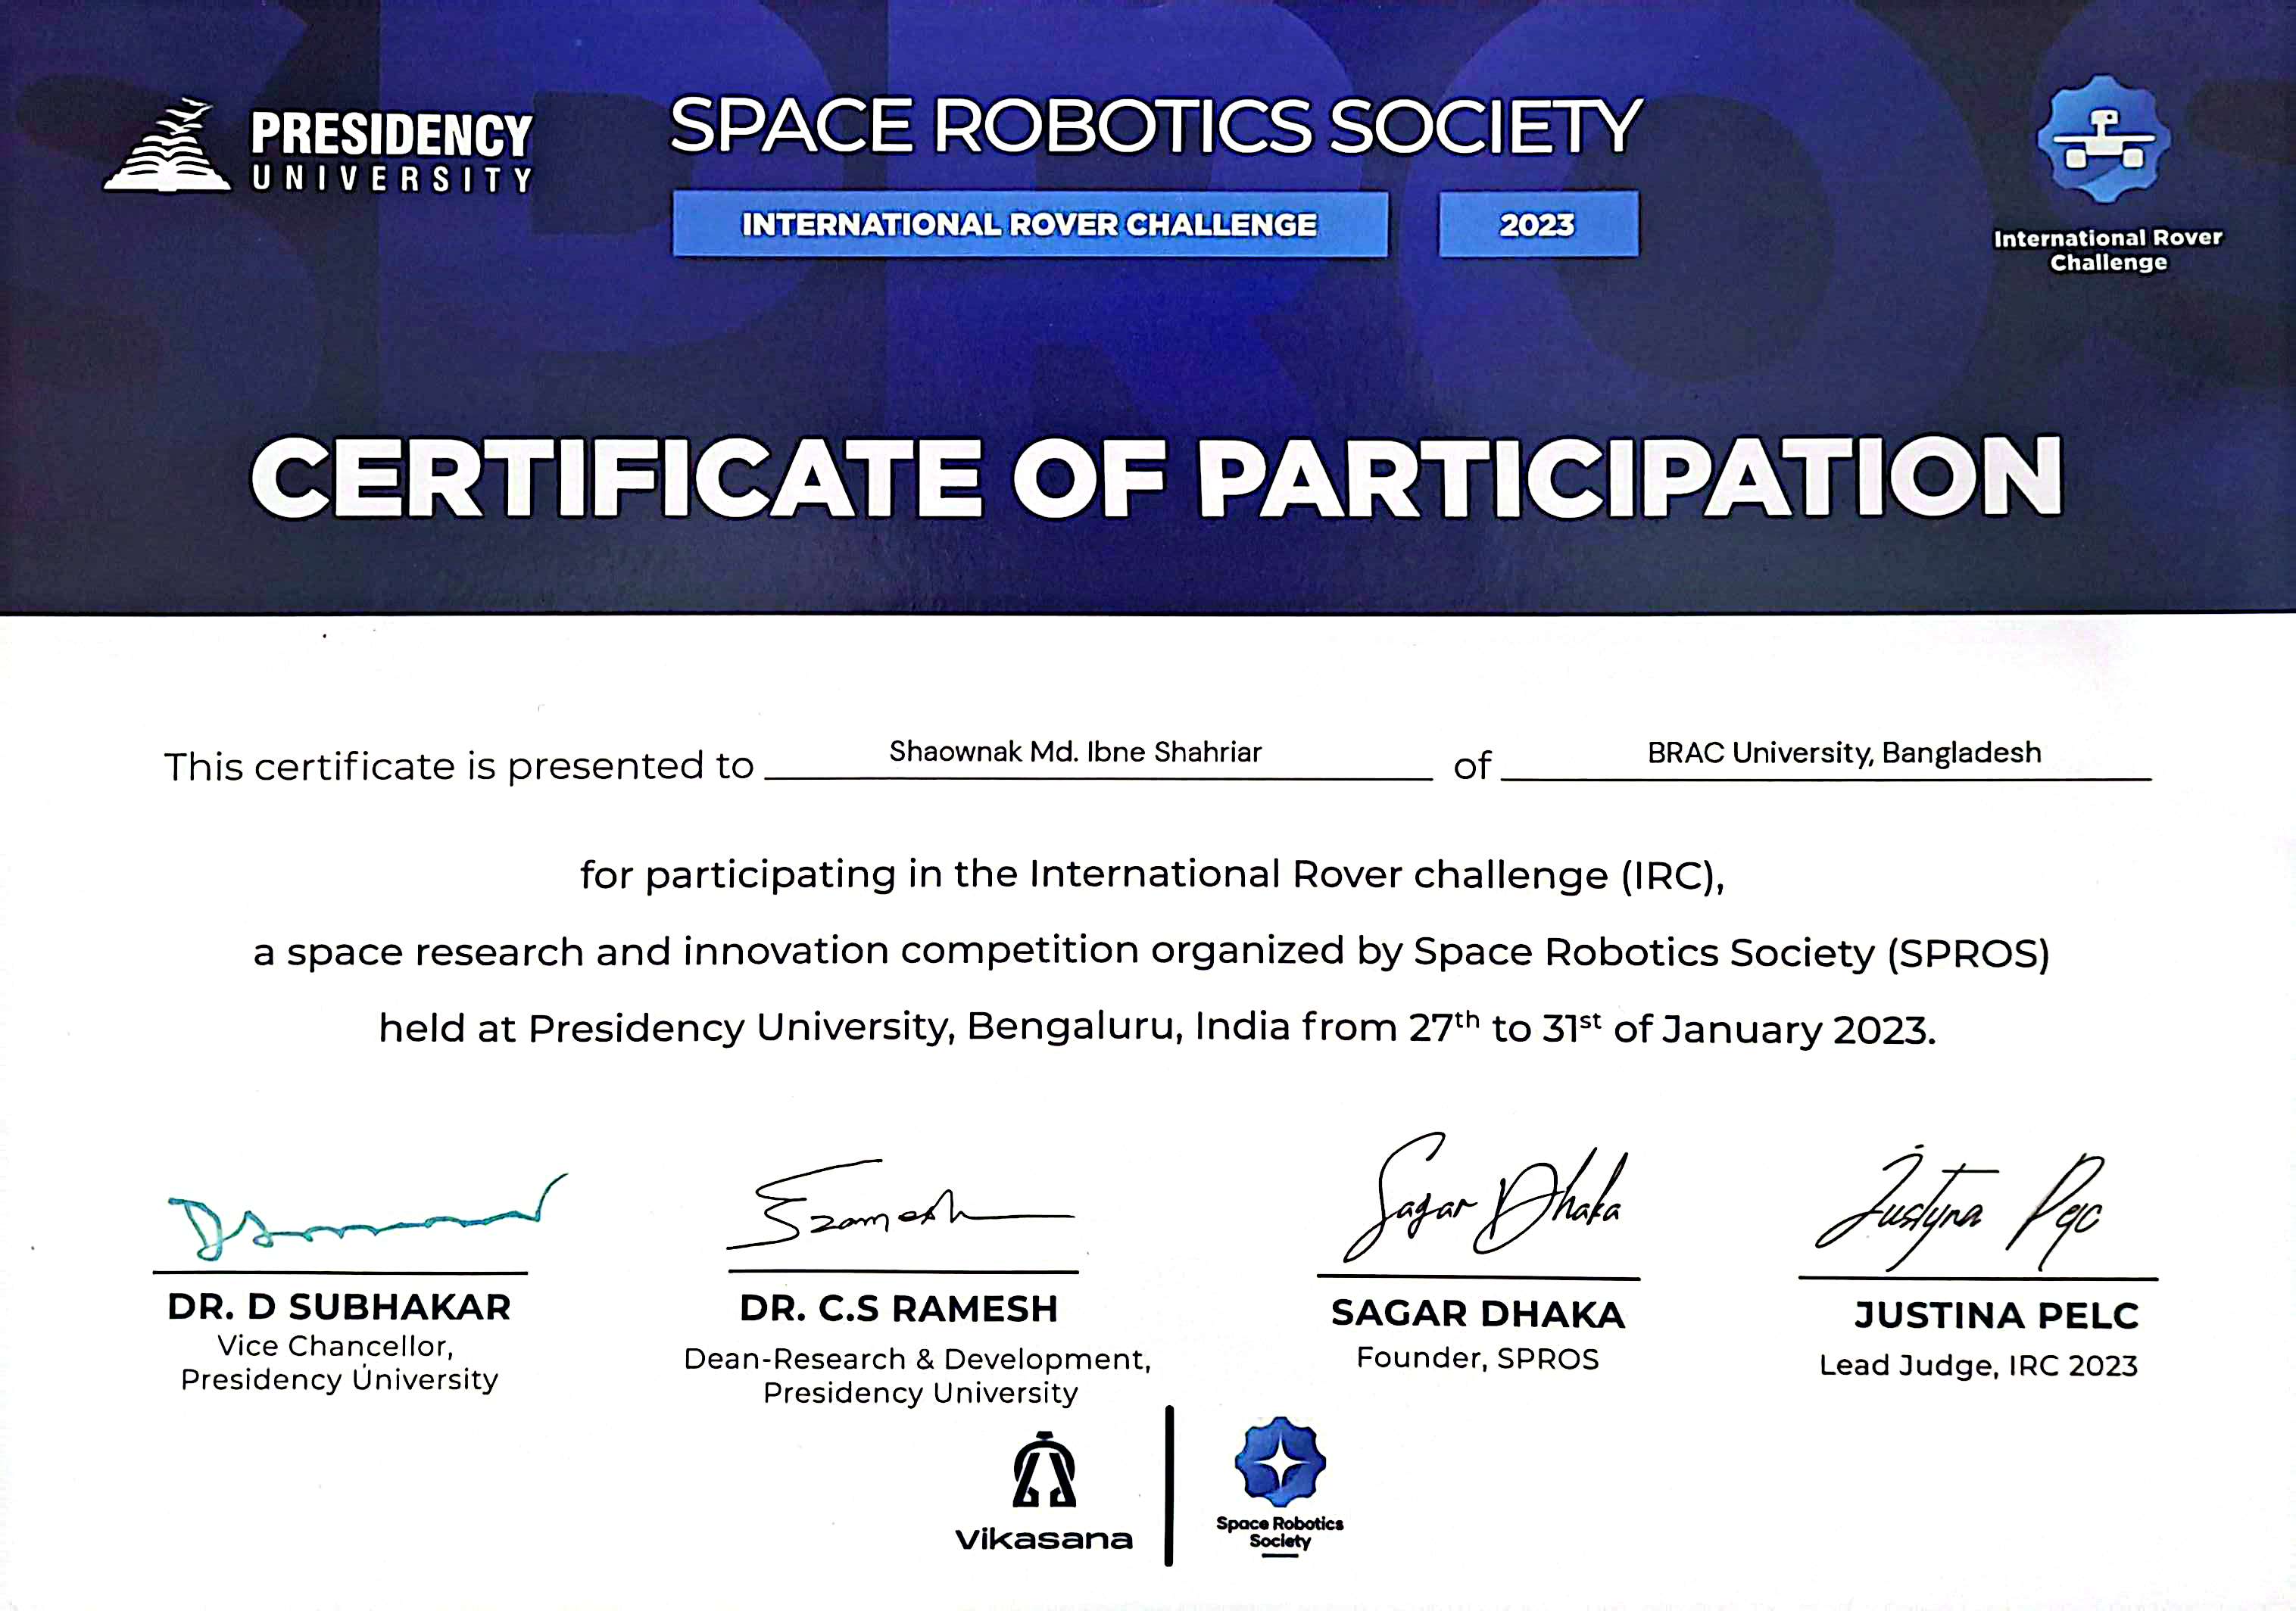
Bangalore, India
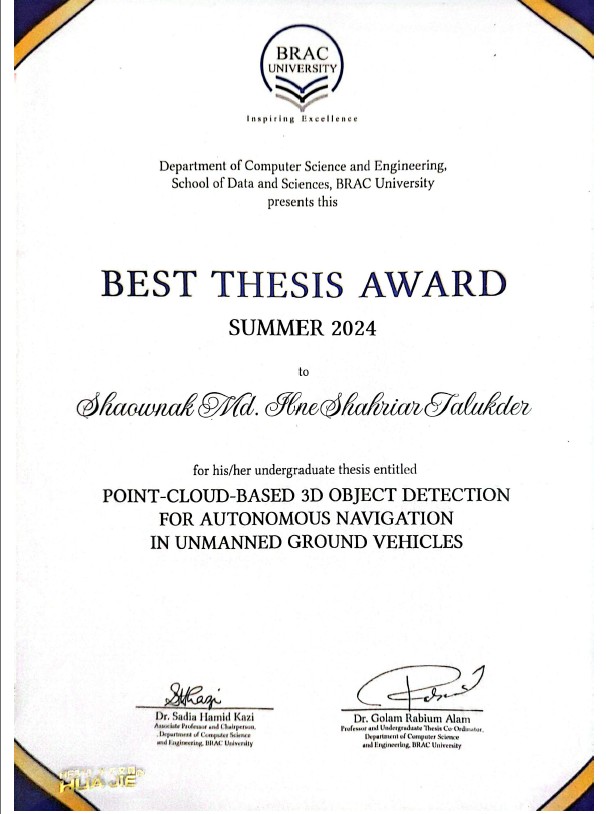
BRAC University
Leicester, England
JAXA (Bangladesh Round)
BRAC University